Learning Where to Look: Active Perception for Autonomous Drones
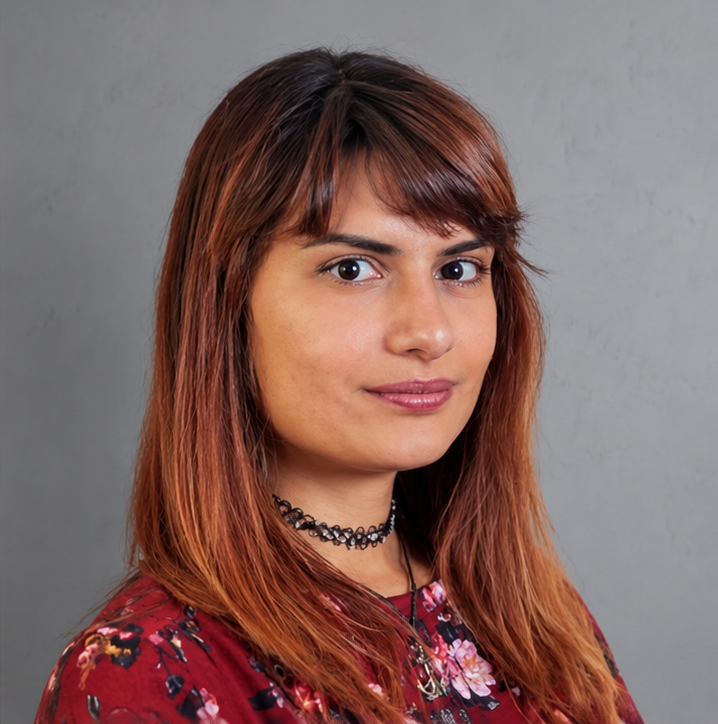
Prof. Marija Popović
TU Delft, The Netherlands
Abstract
Autonomous drones operating in unfamiliar environments must decide where to fly and what to observe to accomplish their missions. Limited flight time, uncertain measurements, and incomplete maps make efficient information gathering a central challenge. Active perception addresses this challenge by coupling sensing and planning, allowing robots to select actions according to the information they provide. This talk presents research on active perception and informative planning for aerial robots, highlighting how probabilistic mapping and learning-based methods enable drones to quantify uncertainty, select informative viewpoints, and adapt their paths as new observations arrive. Particular attention is given to task-relevant sensing under flight and computational constraints. Applications in environmental monitoring, exploration, and 3D reconstruction illustrate these approaches, highlighting methodological developments, experimental findings, and practical lessons for efficient autonomous data collection.
Biography of the speaker
Marija Popović is an Assistant Professor at the Faculty of Aerospace Engineering at TU Delft, where she is part of the Micro Air Vehicle Laboratory. Previously, she was a Junior Research Group Leader at the Cluster of Excellence “PhenoRob” at the University of Bonn and a Research Associate at Imperial College London. She received her Ph.D. from ETH Zurich in 2019. Her research focuses on robotics and artificial intelligence, particularly robotic exploration, active sensing, mapping, computer vision, and machine learning.